Operating a Emergency Medical Services (HEMS) mission inside narrow mountain passes requires extraordinary piloting skill and precise telemetry tracking. When a Leonardo AW139 descends below valley ridgelines at 300 feet AGL, direct line-of-sight RF signals to single receivers are frequently lost due to terrain masking.
The Terrain Masking Challenge on 1090 MHz
The primary signal transmitted by the transponder of an emergency medical helicopter like the Leonardo AW139 is a standard 1090 MHz Mode-S Extended Squitter or short Mode-S frame. Because radio waves at 1.09 GHz propagate strictly via line-of-sight (LOS), granite ridgelines and steep valley walls obstruct RF transmission long before the aircraft lands at an unpaved spot or local hospital helipad. Under standard conditions, ADS-B receivers located on the plains lose lock as soon as the helicopter squawking 7000 or 7700 dips below 1,500 feet inside the valley floor.
TDOA Multilateration: Overcoming Signal Loss
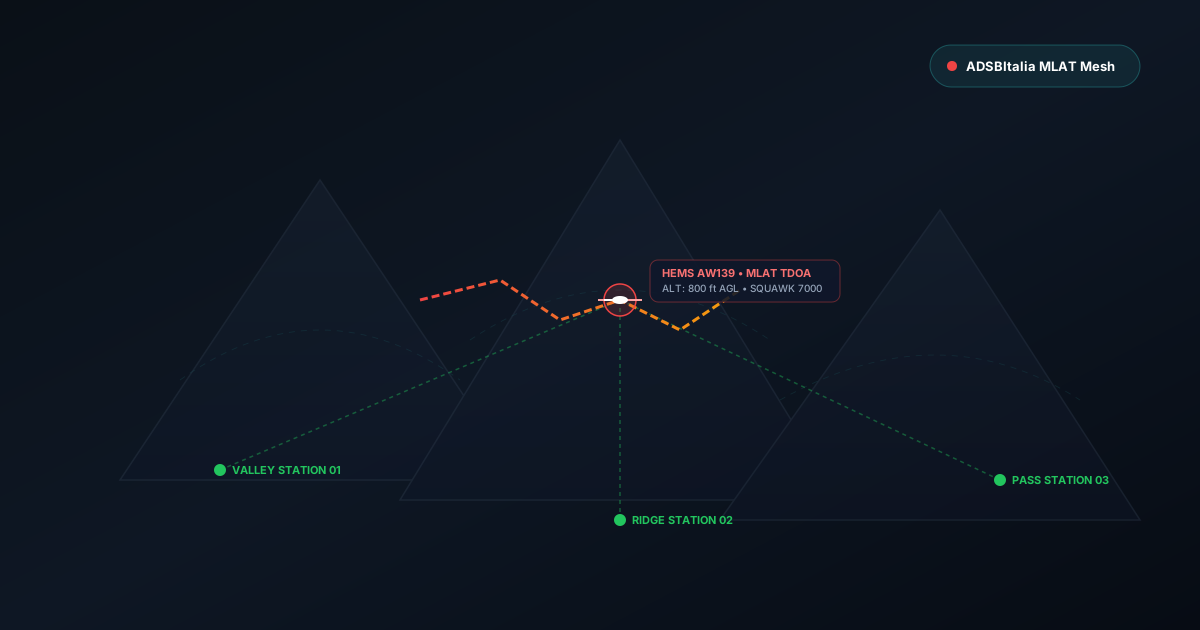
To overcome physical RF masking, the ADSBItalia feeding grid relies on synchronized Multilateration (MLAT) using Time Difference of Arrival (TDOA) algorithms. When an AW139 broadcasts short Mode-S All-Call replies (DF11) or altitude squitters (DF0/DF4), multiple ground feeder nodes surrounding the mountain ridge capture the exact same RF pulse.
To guarantee high-precision positioning during low-altitude HEMS search-and-rescue patterns, the receiving infrastructure must meet strict technical criteria:
- GPS-Disciplined SDR Clocks: Feeder nodes utilize SDRs synchronized with GPS PPS (Pulse Per Second) signals to achieve timing accuracy within 10 nanoseconds.
- High-Rate Processing: Raw frames are decoded via
readsbordump1090-fa, preserving high-resolution timestamp metadata in theBeastoutput format. - Network Topology: Receivers are strategically positioned along ridge peaks and valley openings to form non-collinear geometric baseline arrays.
- Dynamic Hover Tracking: MLAT algorithms handle abrupt transitions from 140-knot valley transit speeds to stationary out-of-ground-effect (OGE) hovers during winch operations.
Real-World Telemetry Reconstructions
During recent SAR operations in the Alpine sector, feeder stations captured an AW139 maintaining a steady wind crab angle while flying a creeping line search pattern inside a narrow gorge. Despite complete masking from distant ADS-B ground stations, the synchronized local MLAT network sustained zero frame drops, providing real-time operational visibility down to 200 feet above ground level.